Mixed-FOV Depth Sensing
Pairing an ultrawide depth sensor with a narrow one for detail where it matters.
 Eddie OffermannHardware prototyping, enclosure, lens calibration, disparity-mapping algorithm, demonstration and report
- Role
- Hardware prototyping, enclosure, lens calibration, disparity-mapping algorithm, demonstration and report
- Areas
- Computer Vision, Hardware, Research, Optics
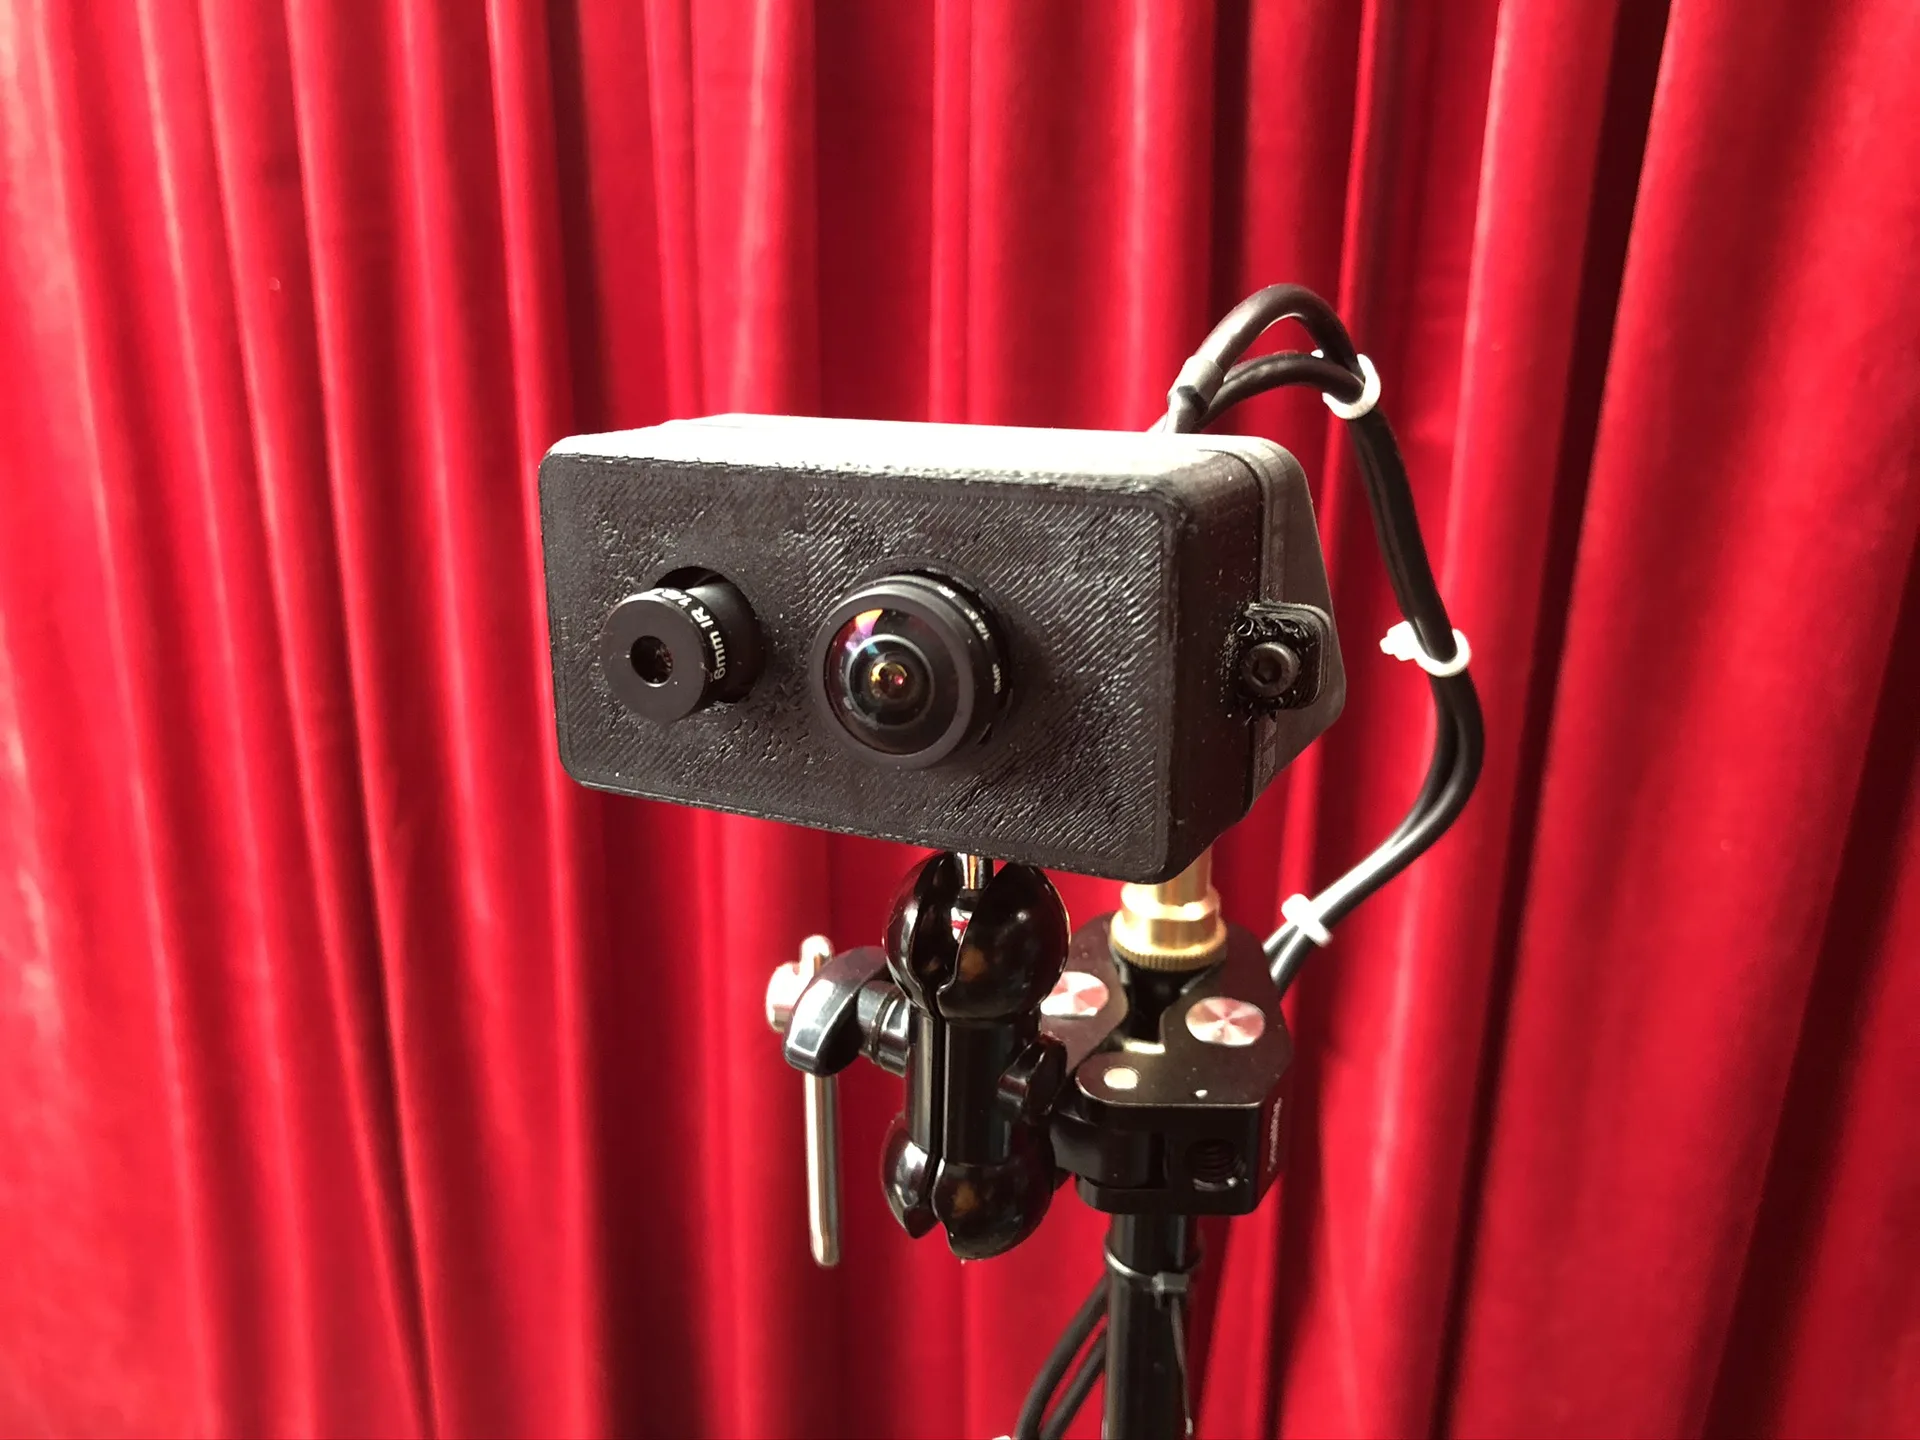
Most depth setups pair matching sensors. This exploration broke with that to measure the effect of combining two depth sensors with different fields of view.
The question came from a hardware product that already had one ultrawide sensor. The study looked at what adding a narrower sensor would gain in detailed depth for the central region.

We built the prototype hardware and its 3D-printed enclosure, which holds a small narrow lens and a large fisheye side by side, the lens calibration stack and a custom disparity-mapping algorithm, then demonstrated the results and wrote them up in a report.

Part of Enhanced Presence.
Gallery

The same scene from both sensors: the ultrawide view and the narrow, detailed center. 
The prototype on a desktop tripod. 
The enclosure keeps both cameras fixed relative to each other for calibration. 
Mounted on a stand for testing. 
The rear of the enclosure. 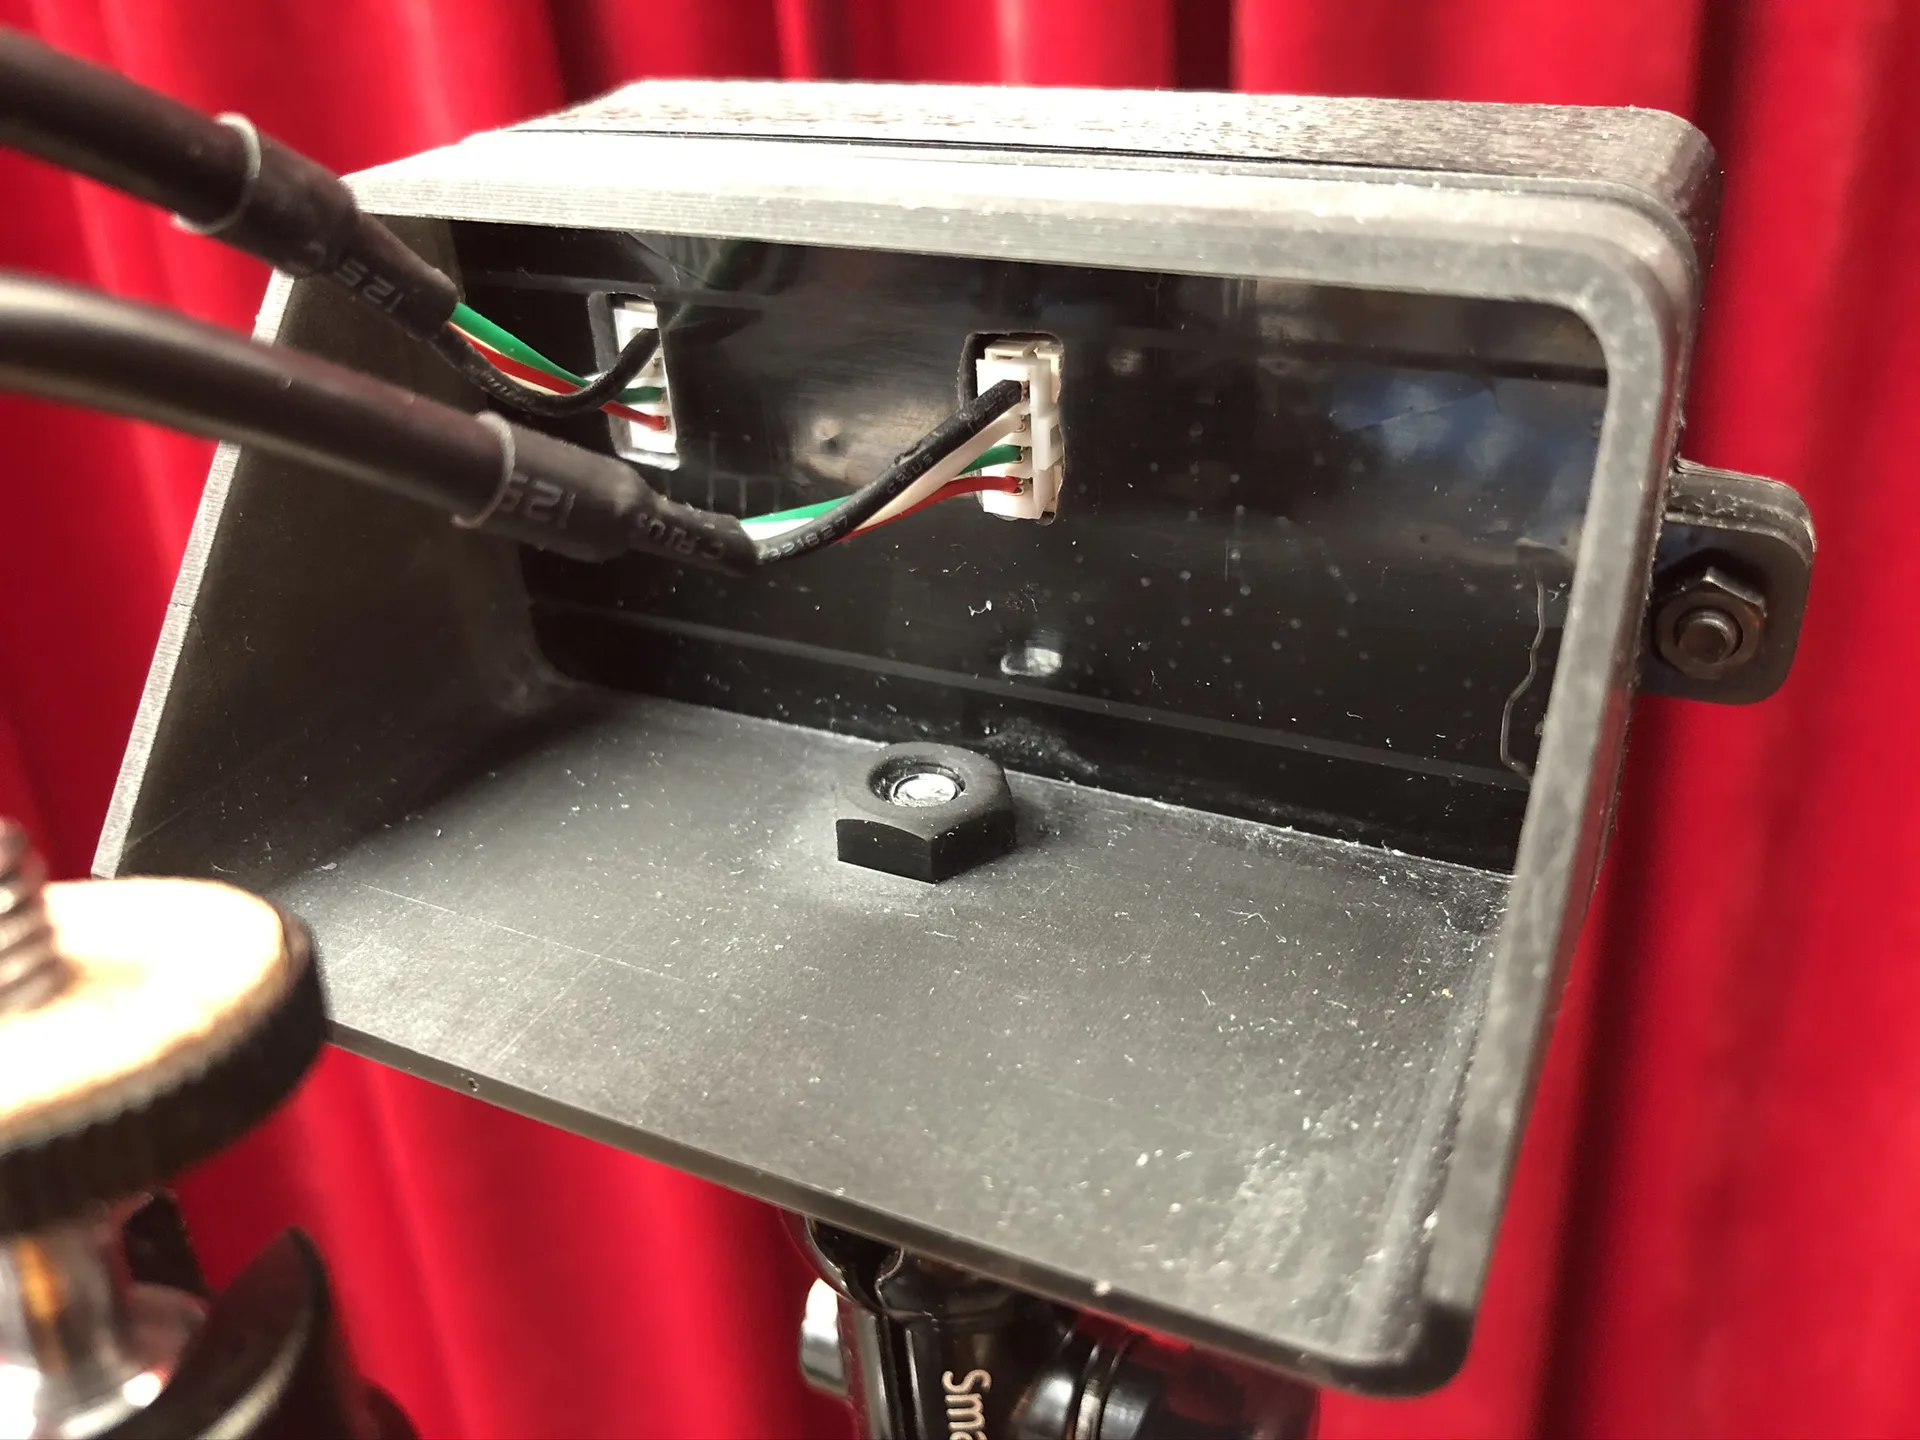
Inside: the two camera boards and their cabling. 
The stand mount from behind.
Related work
-

Computational Optics
Hyperspectral images from the ordinary camera in a phone.
-
HoloFlect
A modular, upgradeable AR headset platform built for enterprise.
-

ISO-5 Optical Cleanroom
A cleanroom lab built to turn phone cameras into spectral instruments.
-
Variable-Baseline Depth Sensing
What happens to depth estimation when the cameras are very far apart?